Physical AI has a blind spot: touch
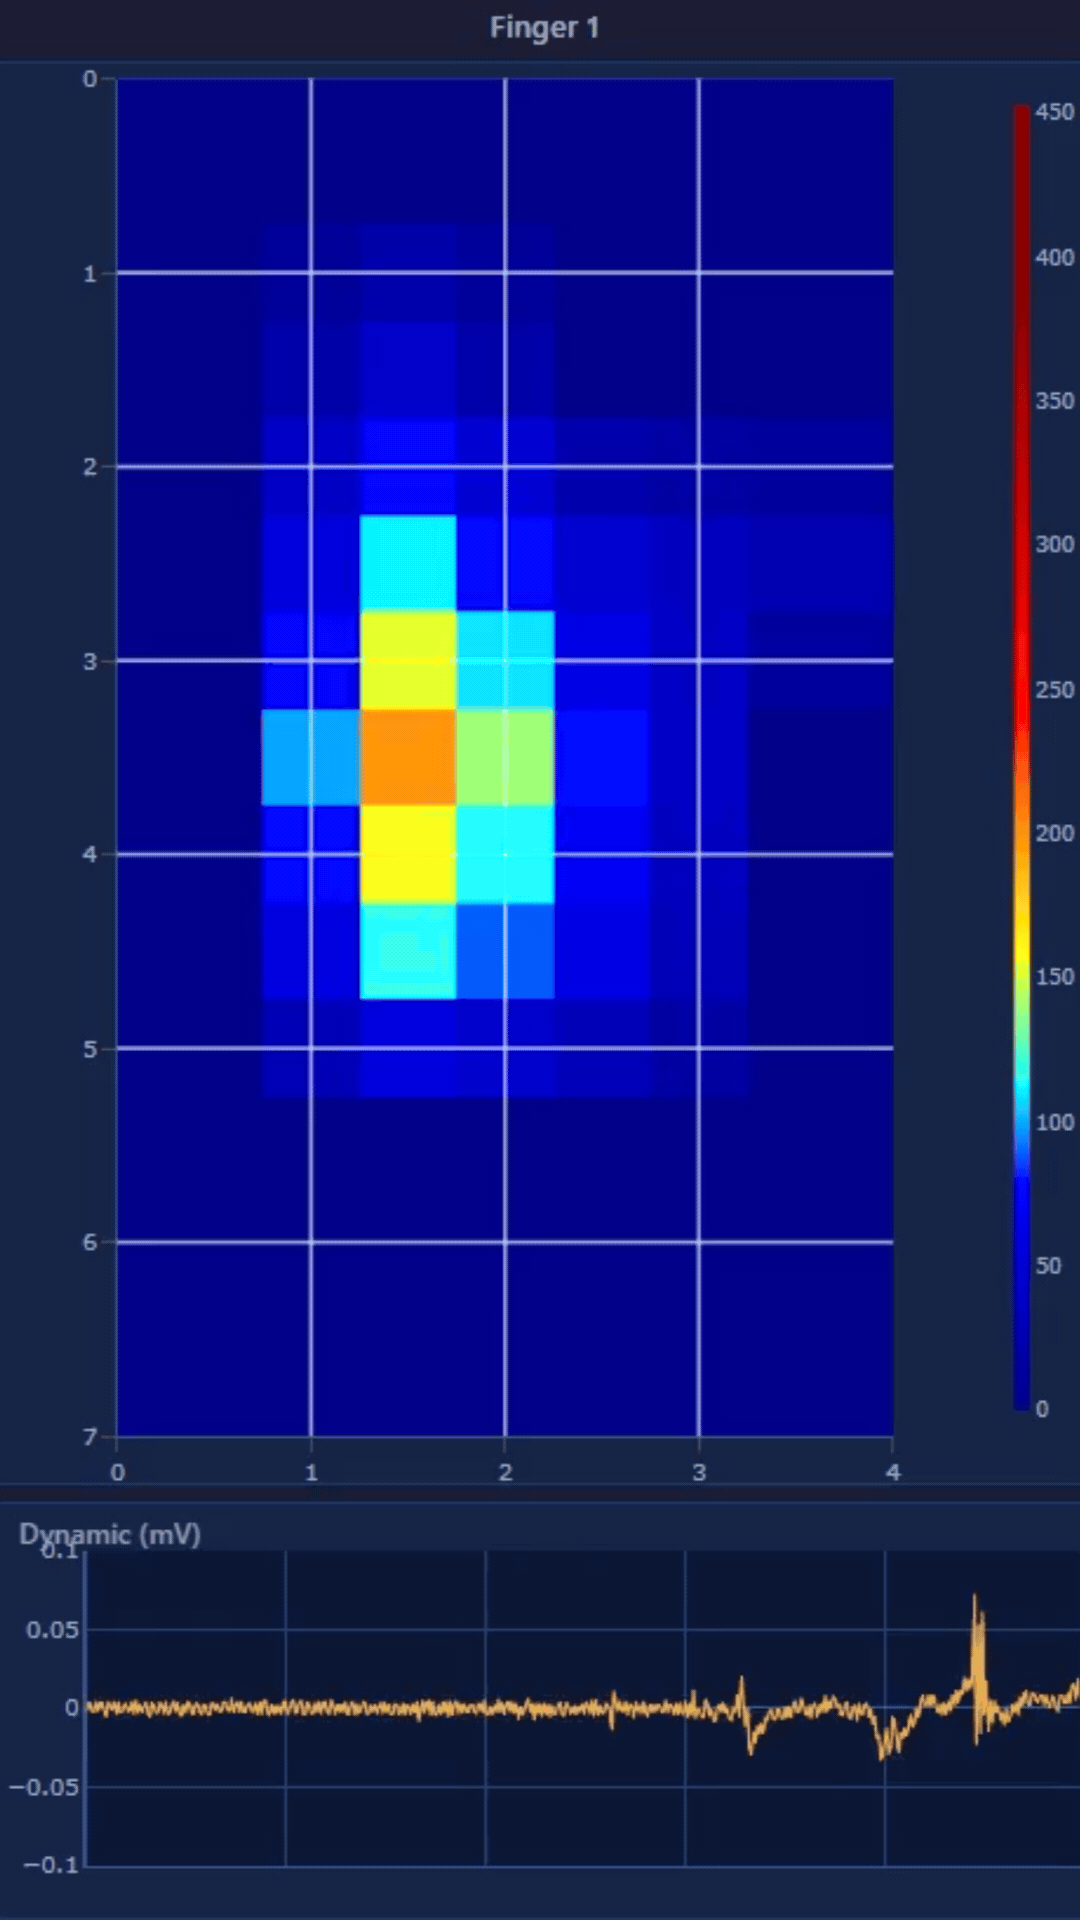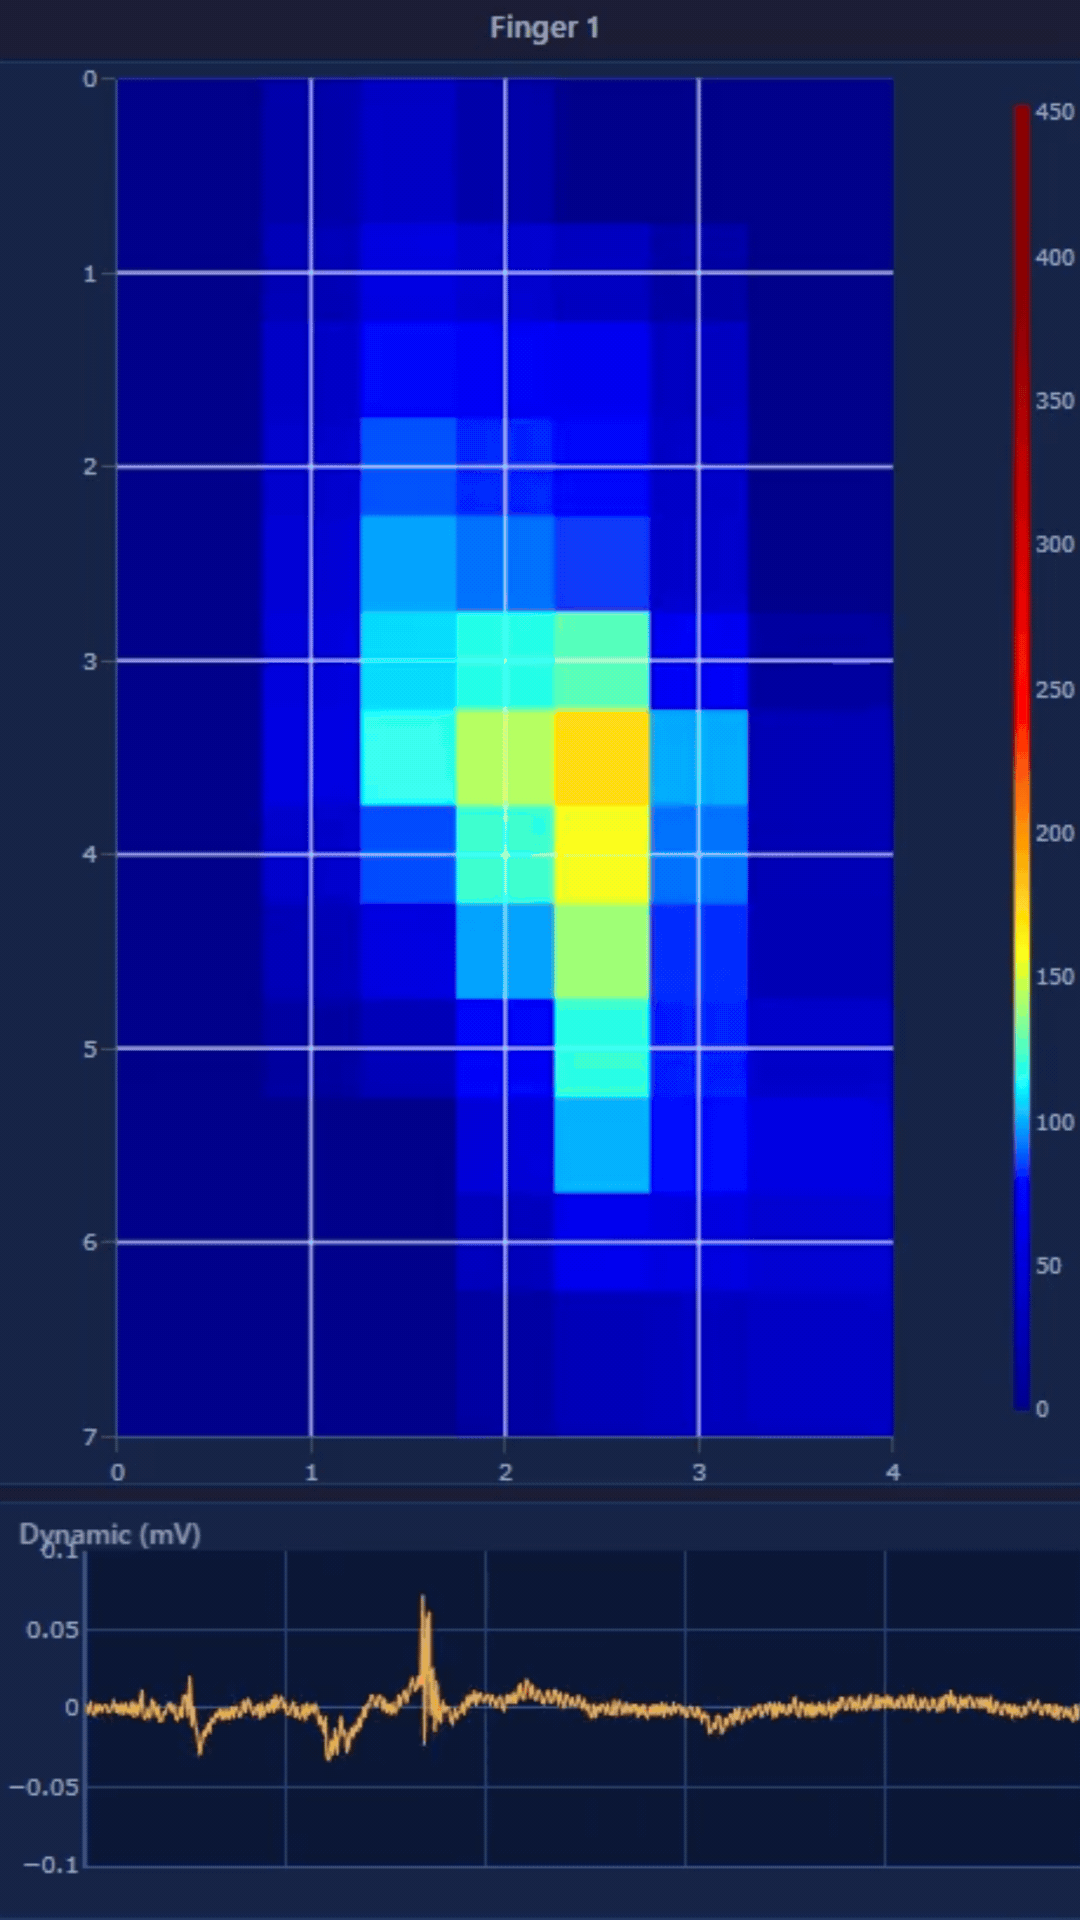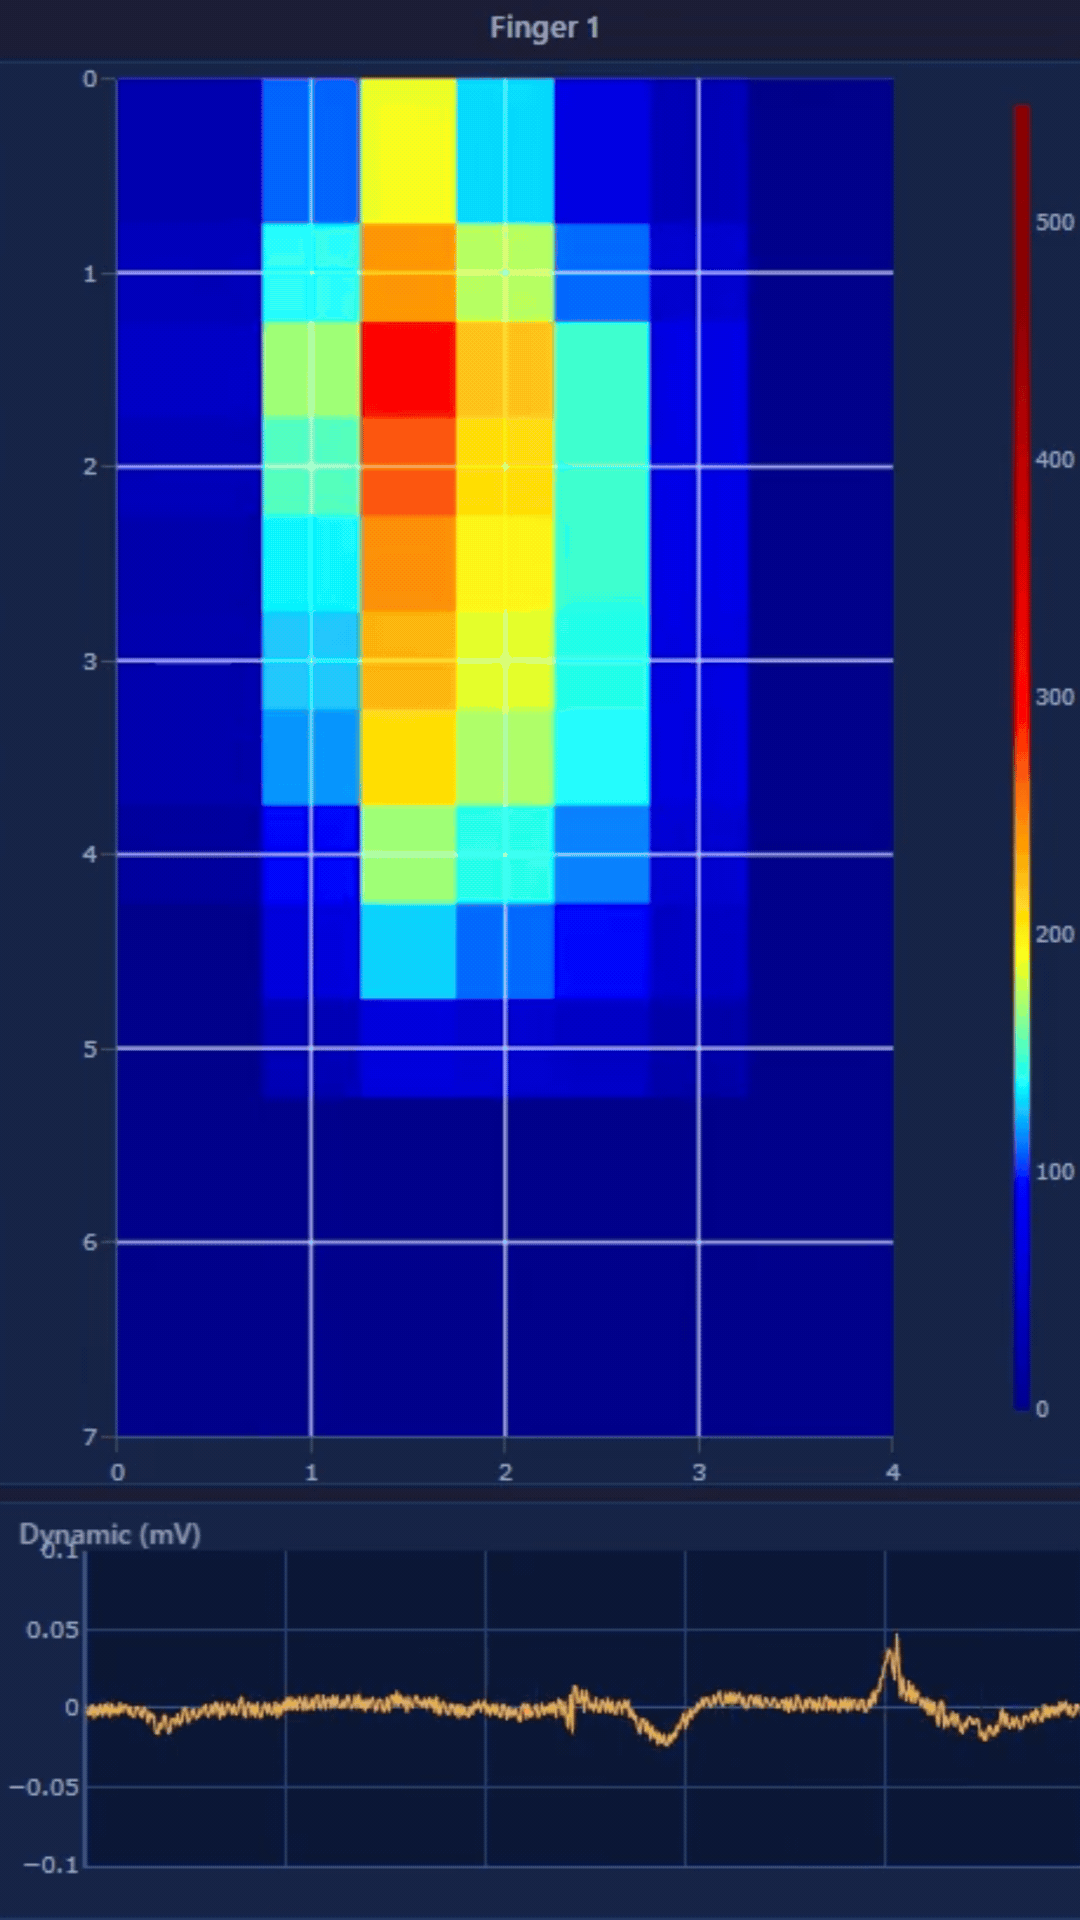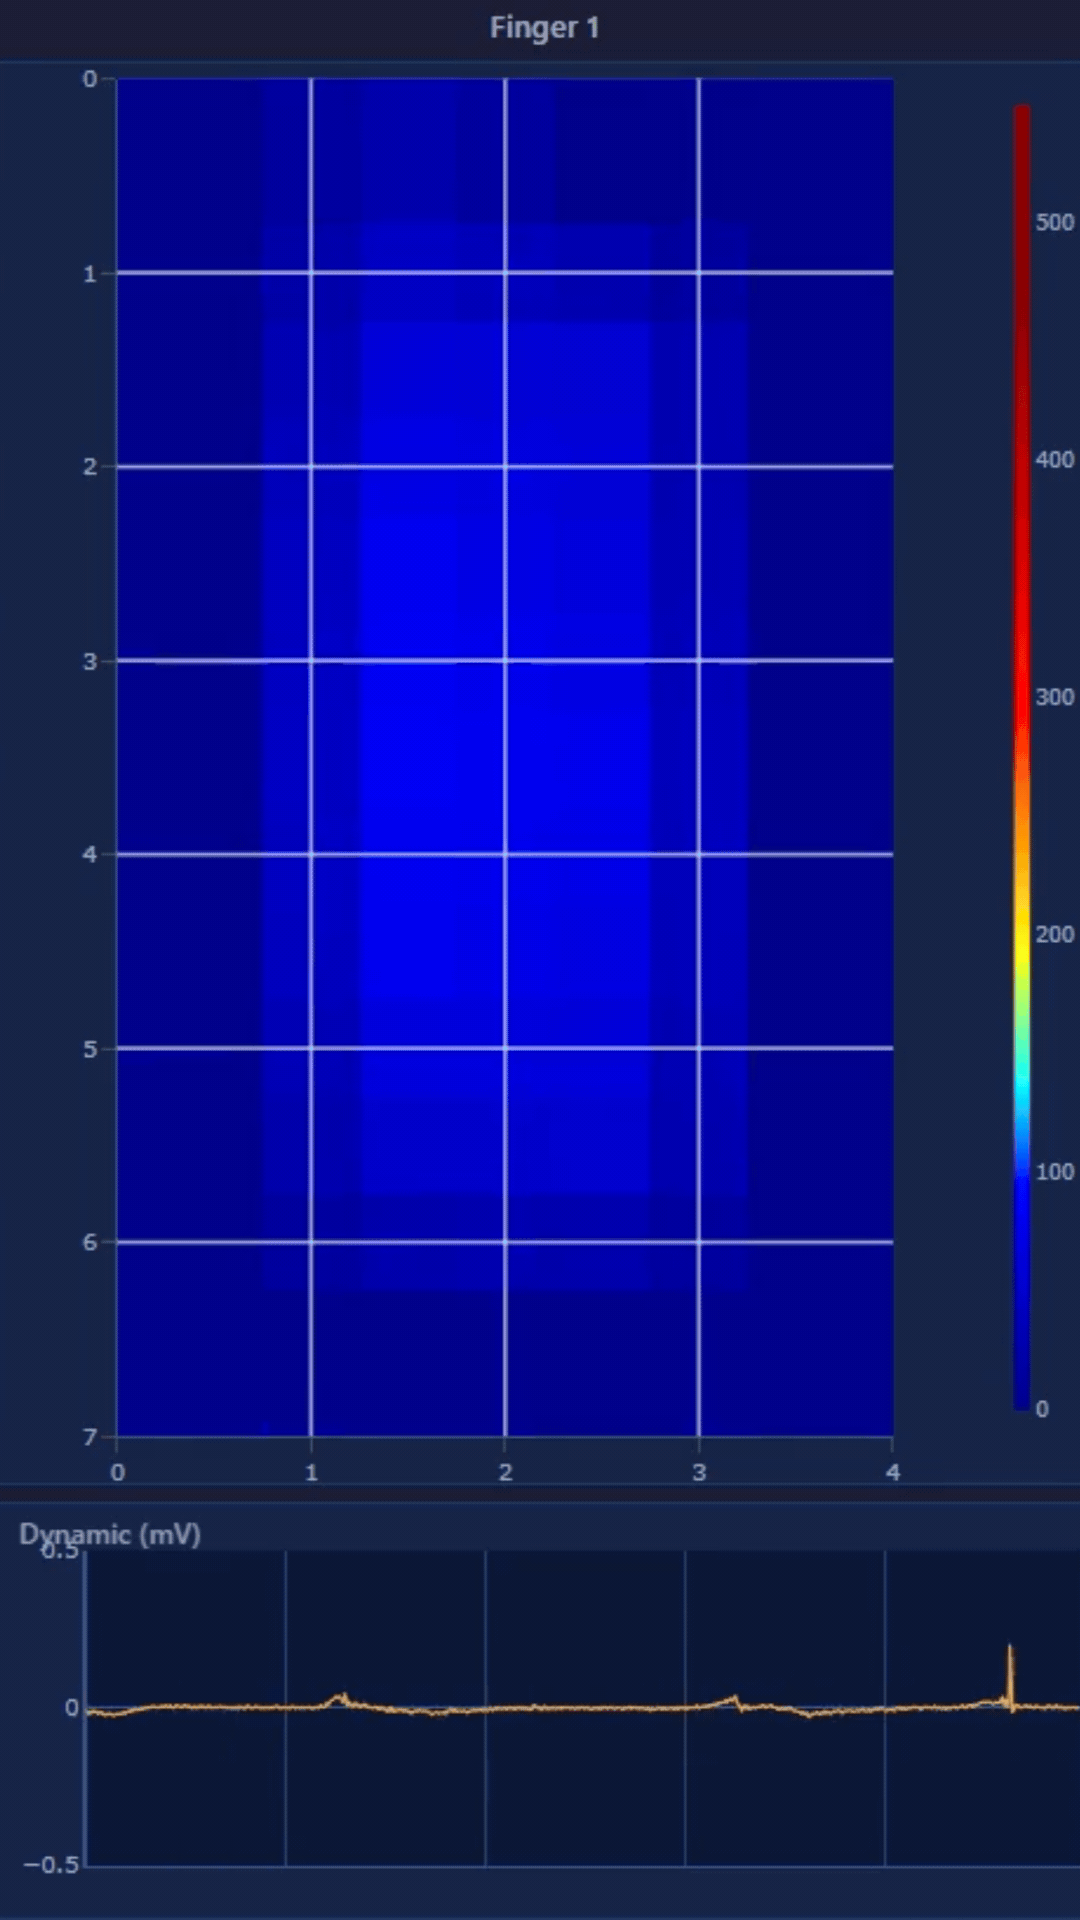
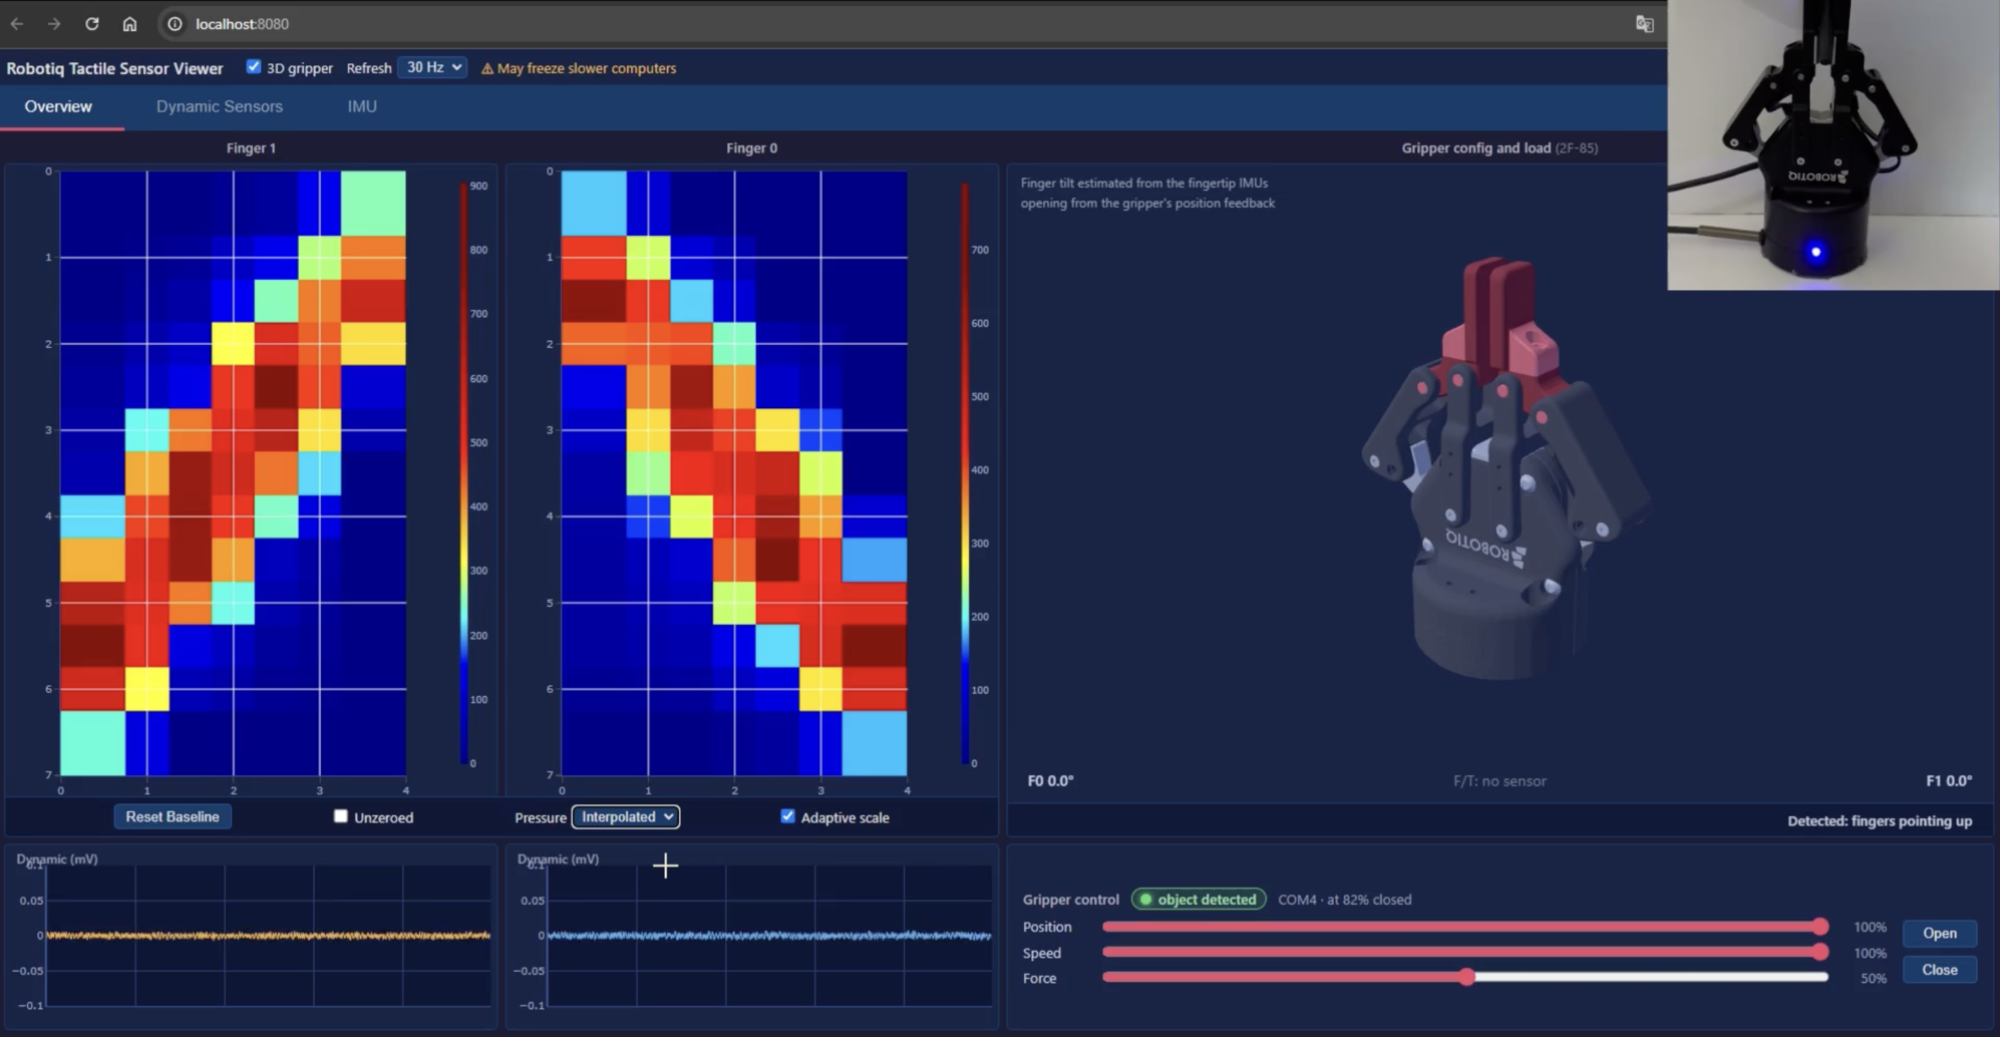
The industry is investing in vision, demonstrations and simulation, yet manipulation depends on touch. Most robots cannot feel what they grasp, so pressure, slip, force and position go uncaptured.
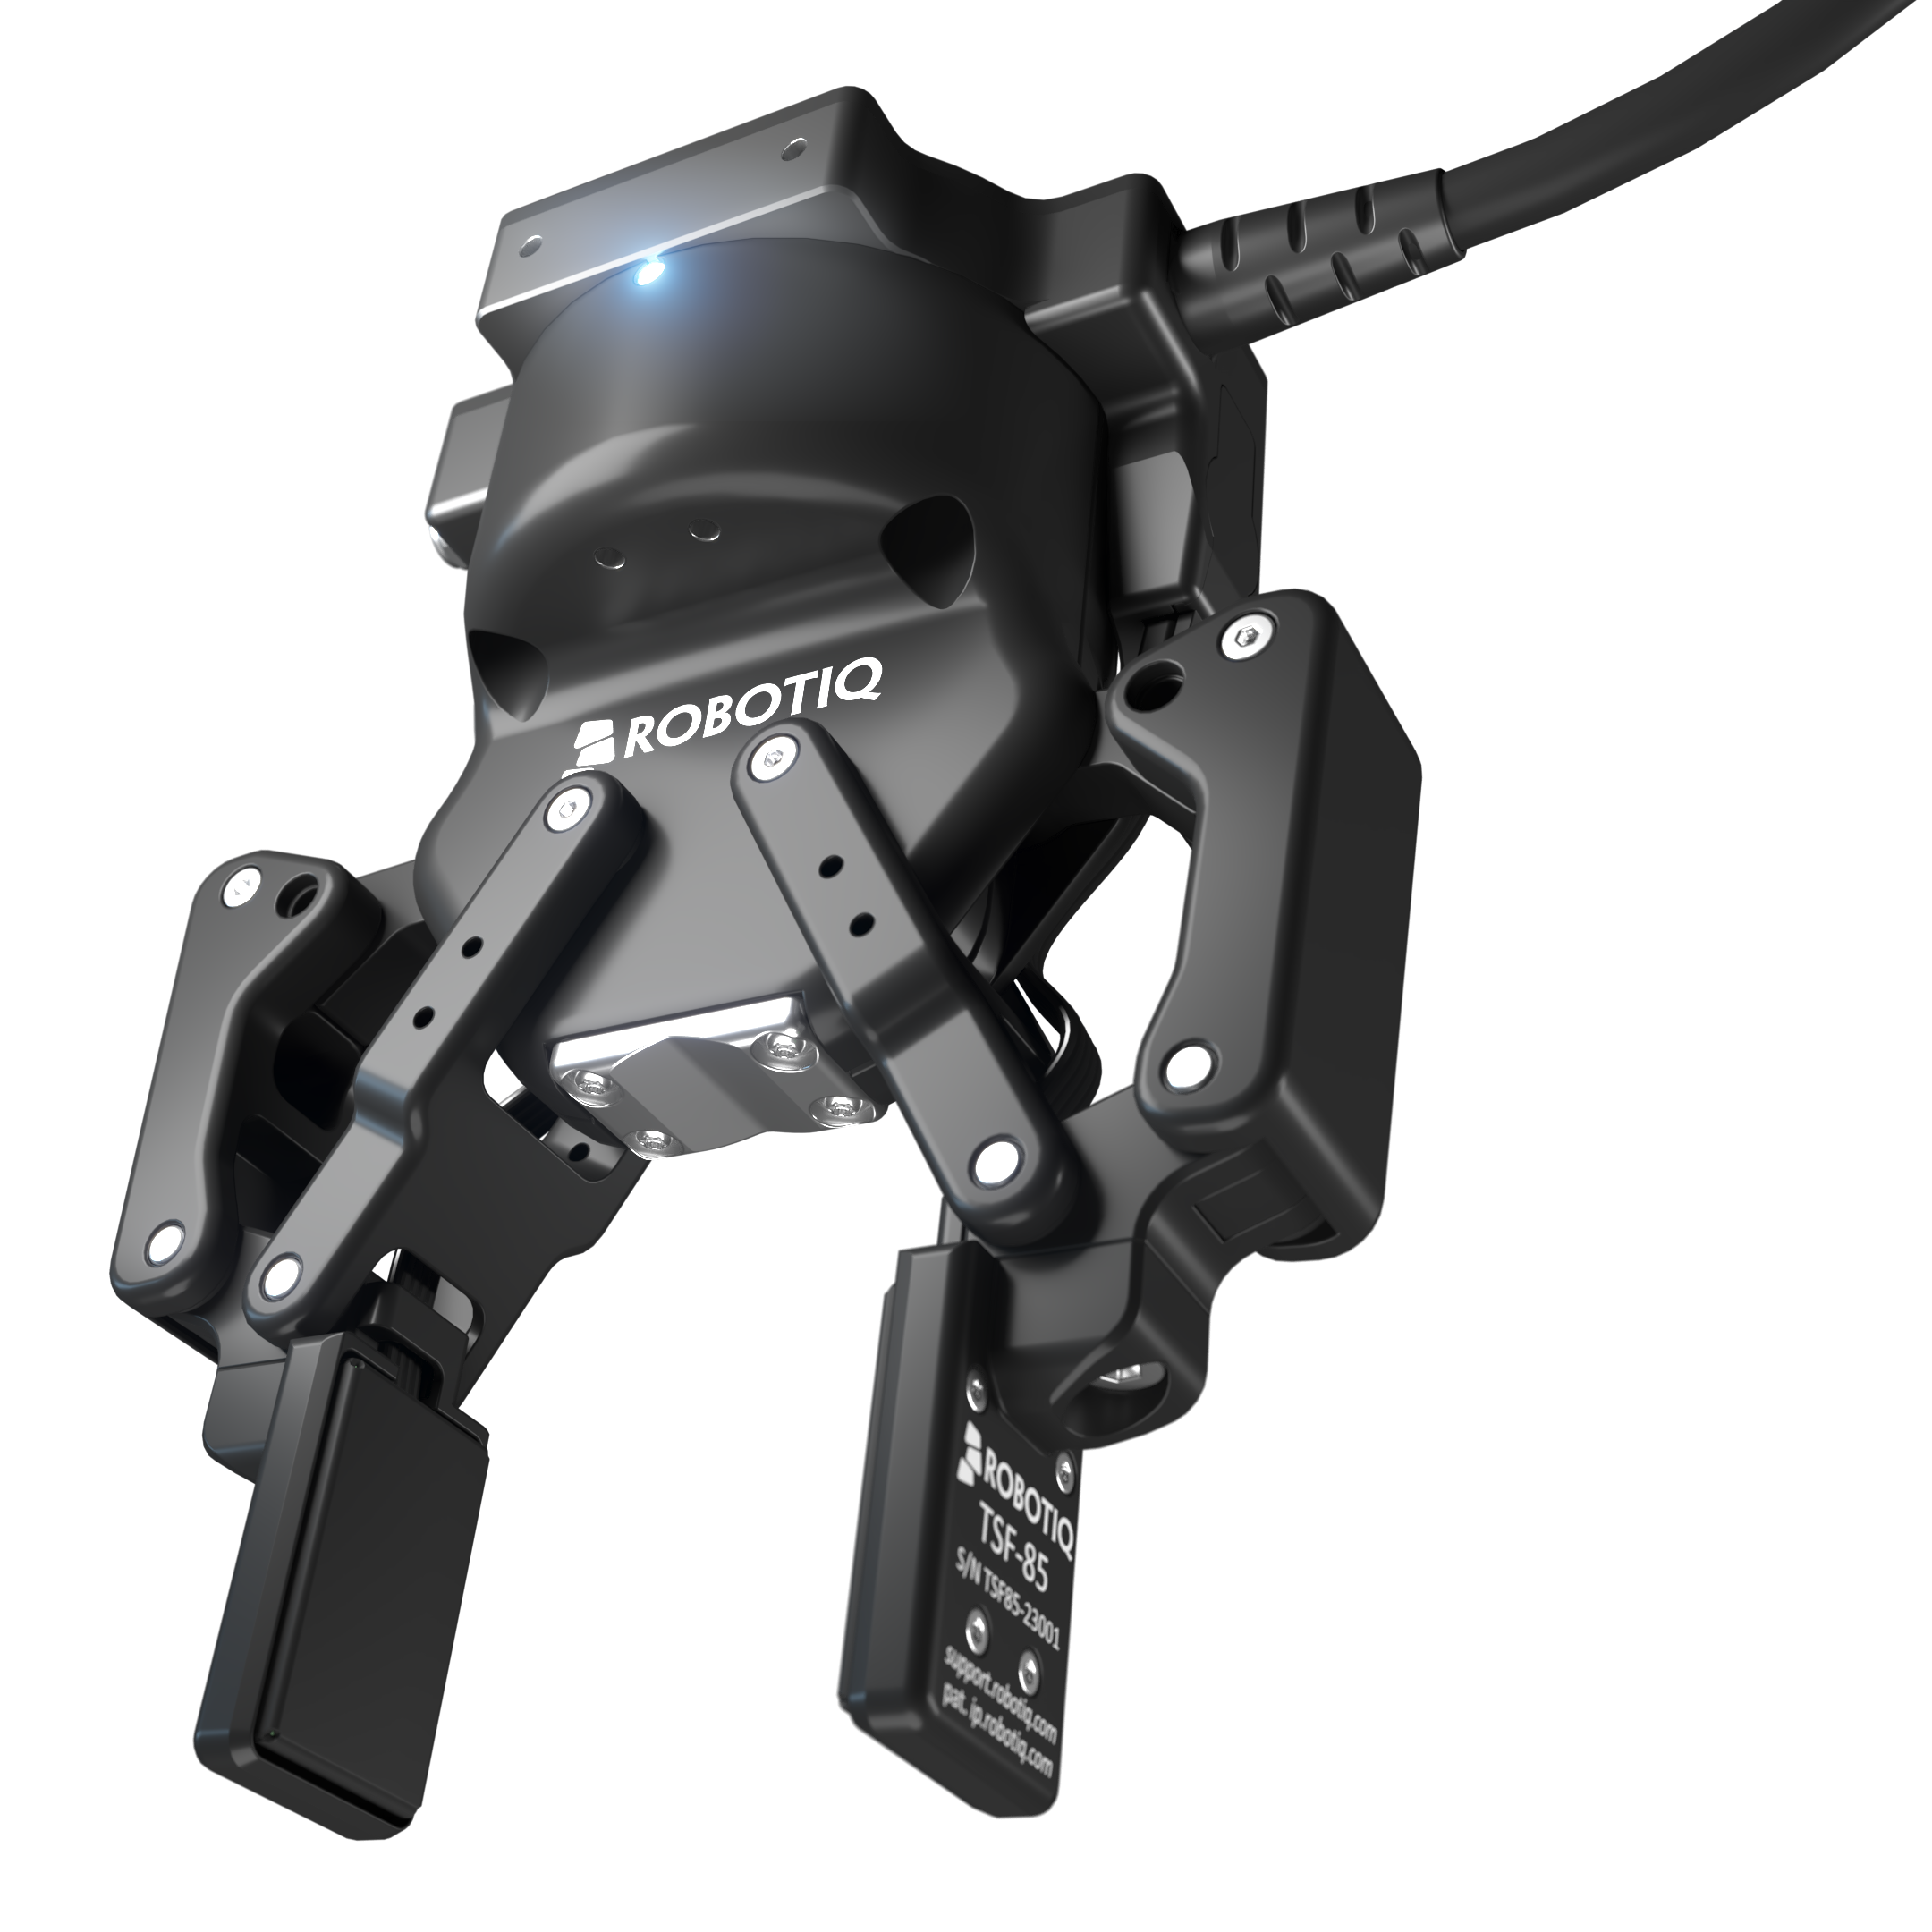
Tactile sensing is not new; turning raw signal into training data and real-time behavior is the hard part. The 2FC captures contact-rich data, synchronized and labeled with physical events, and runs embedded intelligence on the gripper so robots act on what they feel.